Felipe Polido

Building the engine of American infrastructure.

I lead robotics, software, and manufacturing at Reframe Systems, where we build software-defined microfactories for the built environment.

Now
Co-Founder & CTO, Reframe Systems
Before
Sparrow tech lead, Amazon Robotics · HyQ quadrupeds, IIT · Atlas humanoid, DARPA Robotics Challenge
Felipe Polido
01

Reframe Systems

reframe.systems · Co-founded 2022 · Feb 2023 – Present

We need to learn to love building again in the US. We are short on homes, power plants, data centers, and the factories that make all of it. Since 1970, US manufacturing productivity has grown about ninefold while construction productivity has fallen, roughly 1% a year. And about 41% of the construction workforce is expected to retire by 2031. Housing and public works will keep getting more expensive unless we change how we build.

We build software-defined factories that turn a design model into a finished building.

Robotic work cell framing a wall panel · US 12,715,136, FIG. 13
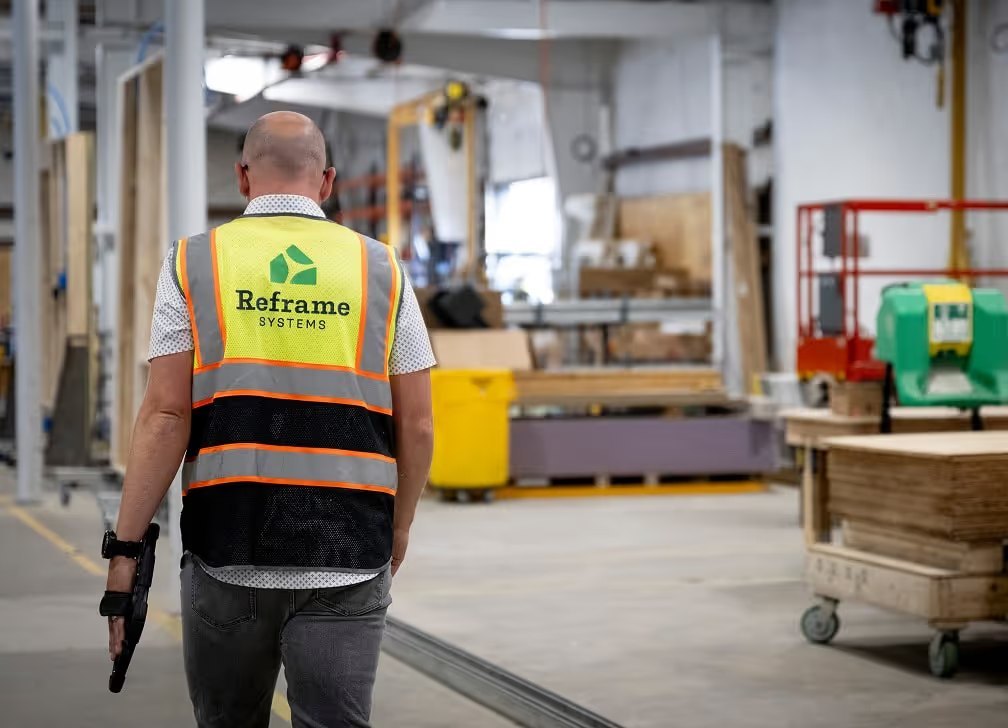
Walking the floor of a Reframe Systems microfactory
Microfactory floor
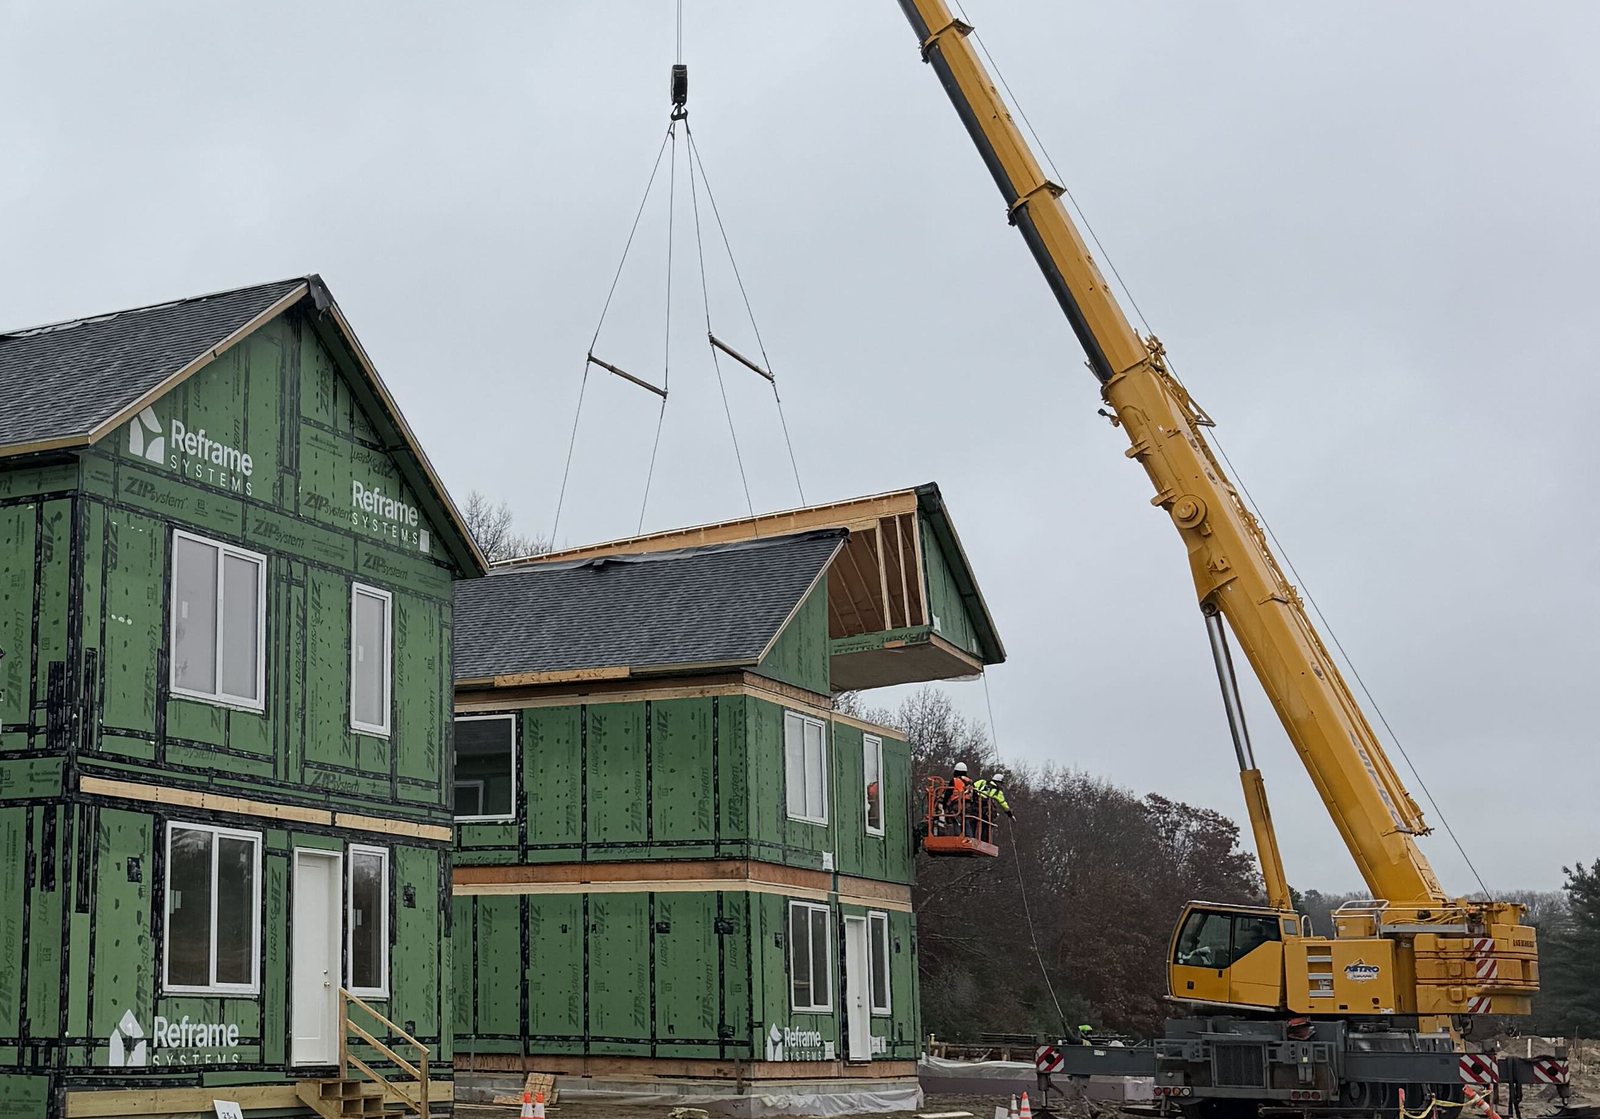
A crane setting a roof module onto a Reframe Systems home at Adams Circle
Roof set, Adams Circle
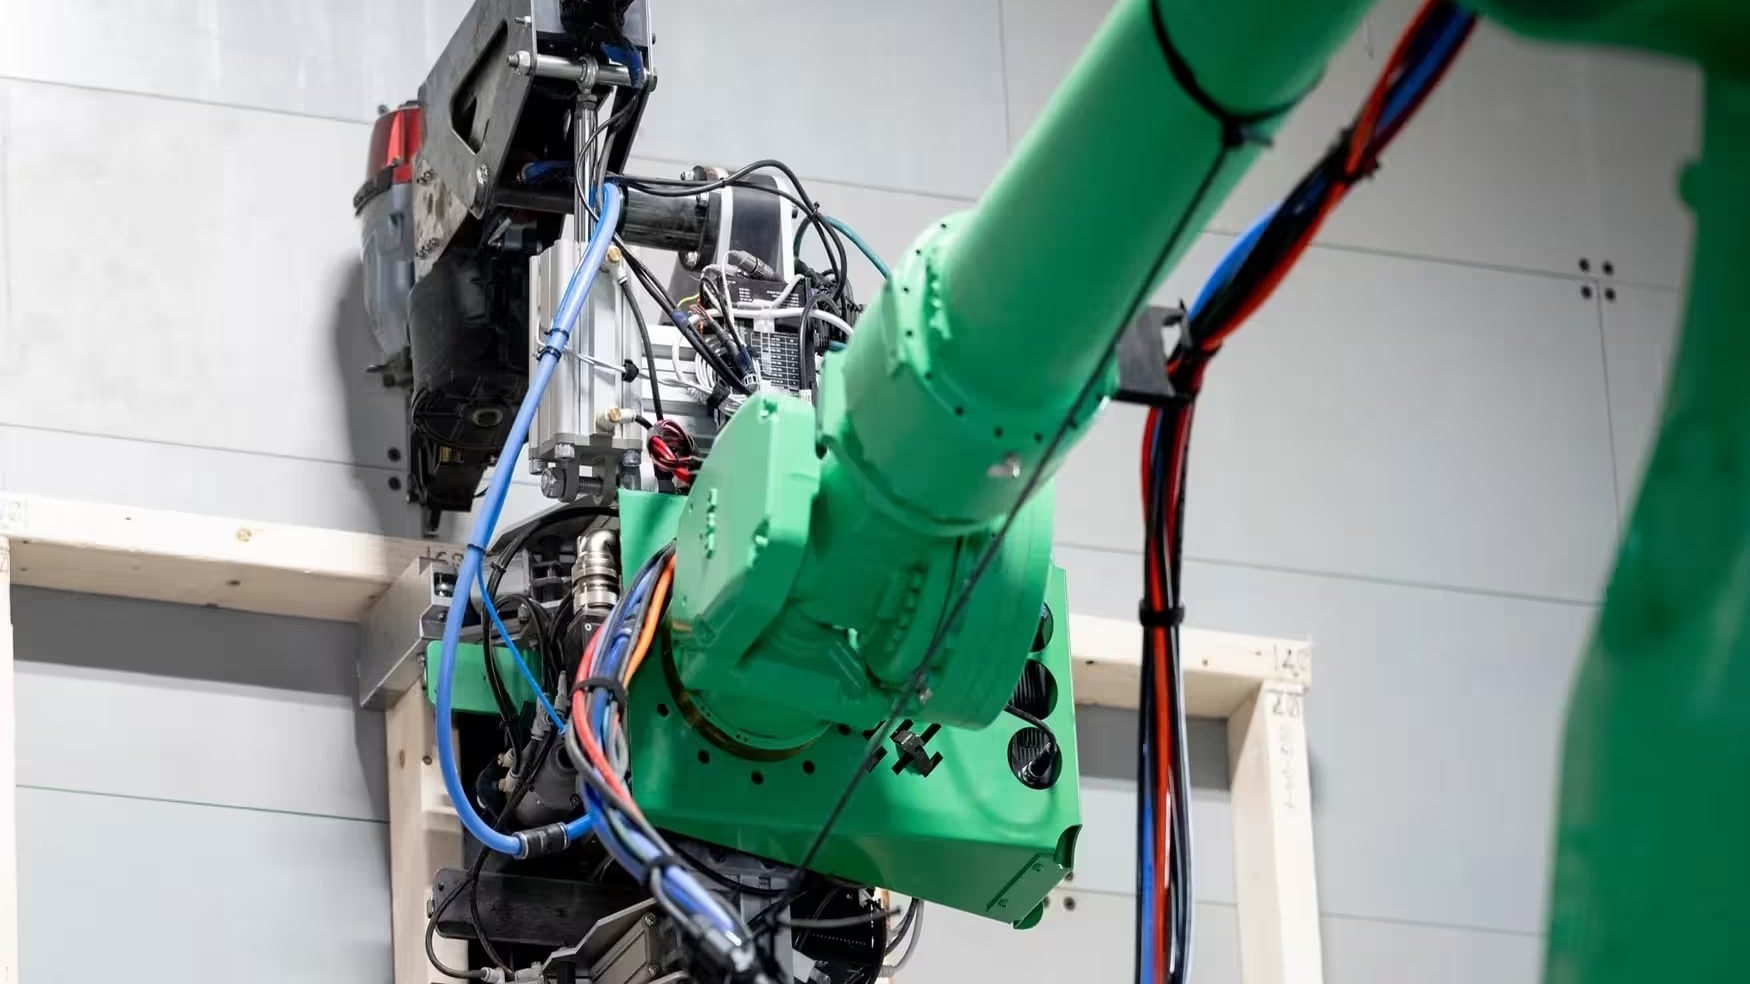
Robotic arm framing a wall panel in a Reframe Systems microfactory
Robotic framing

I co-founded Reframe in 2022 with Vikas Enti (CEO) and Aaron Small (Head of Operations and Digital AI). I lead Manufacturing, Software, and Robotics.

Every part we build starts as a released design model. Our software turns it into machine files, robot programs and work instructions, and schedules it on the line. Nobody redraws anything by hand. Our robotic cells frame wall panels every day in production.

FAB1 is our new factory in Billerica, MA. We got the keys, and 70 days later the first part came off the line (we had planned for 120). Total equipment cost was under $5M. And we designed it to be copied... the next one gets the same layout and the same software, close to wherever the next customer is.

Housing first

Housing is the first product. 10 homes delivered so far, from ADUs to triple-deckers, and 114 more units in the pipeline.

None of this is specific to housing. A wall panel is the same job whether it ends up in an apartment or in workforce housing next to a new power plant. The model-to-factory pipeline also works for the buildings behind energy and data centers, and for the carts and fixtures the factory itself runs on. That is where this goes next.

In the Press

More coverage
02

Previously

2016–2023Aug 2016 – Jan 2023

Senior Robotics System Developer Engineer

Amazon Robotics

Technical Lead for the Sparrow Program, Amazon Robotics' flagship item manipulation system. I built vision-based robotic solutions for singulation, dense packing, item identification, and damage detection, deployed across hundreds of thousands of robotic units in Amazon's fulfillment network.

From the drawings of US 12,528,653

Press and video
2013–2015Dec 2013 – Jun 2015

Senior Robotics Engineer, Humanoid Manipulation

WPI-CMU DARPA Robotics Challenge Team

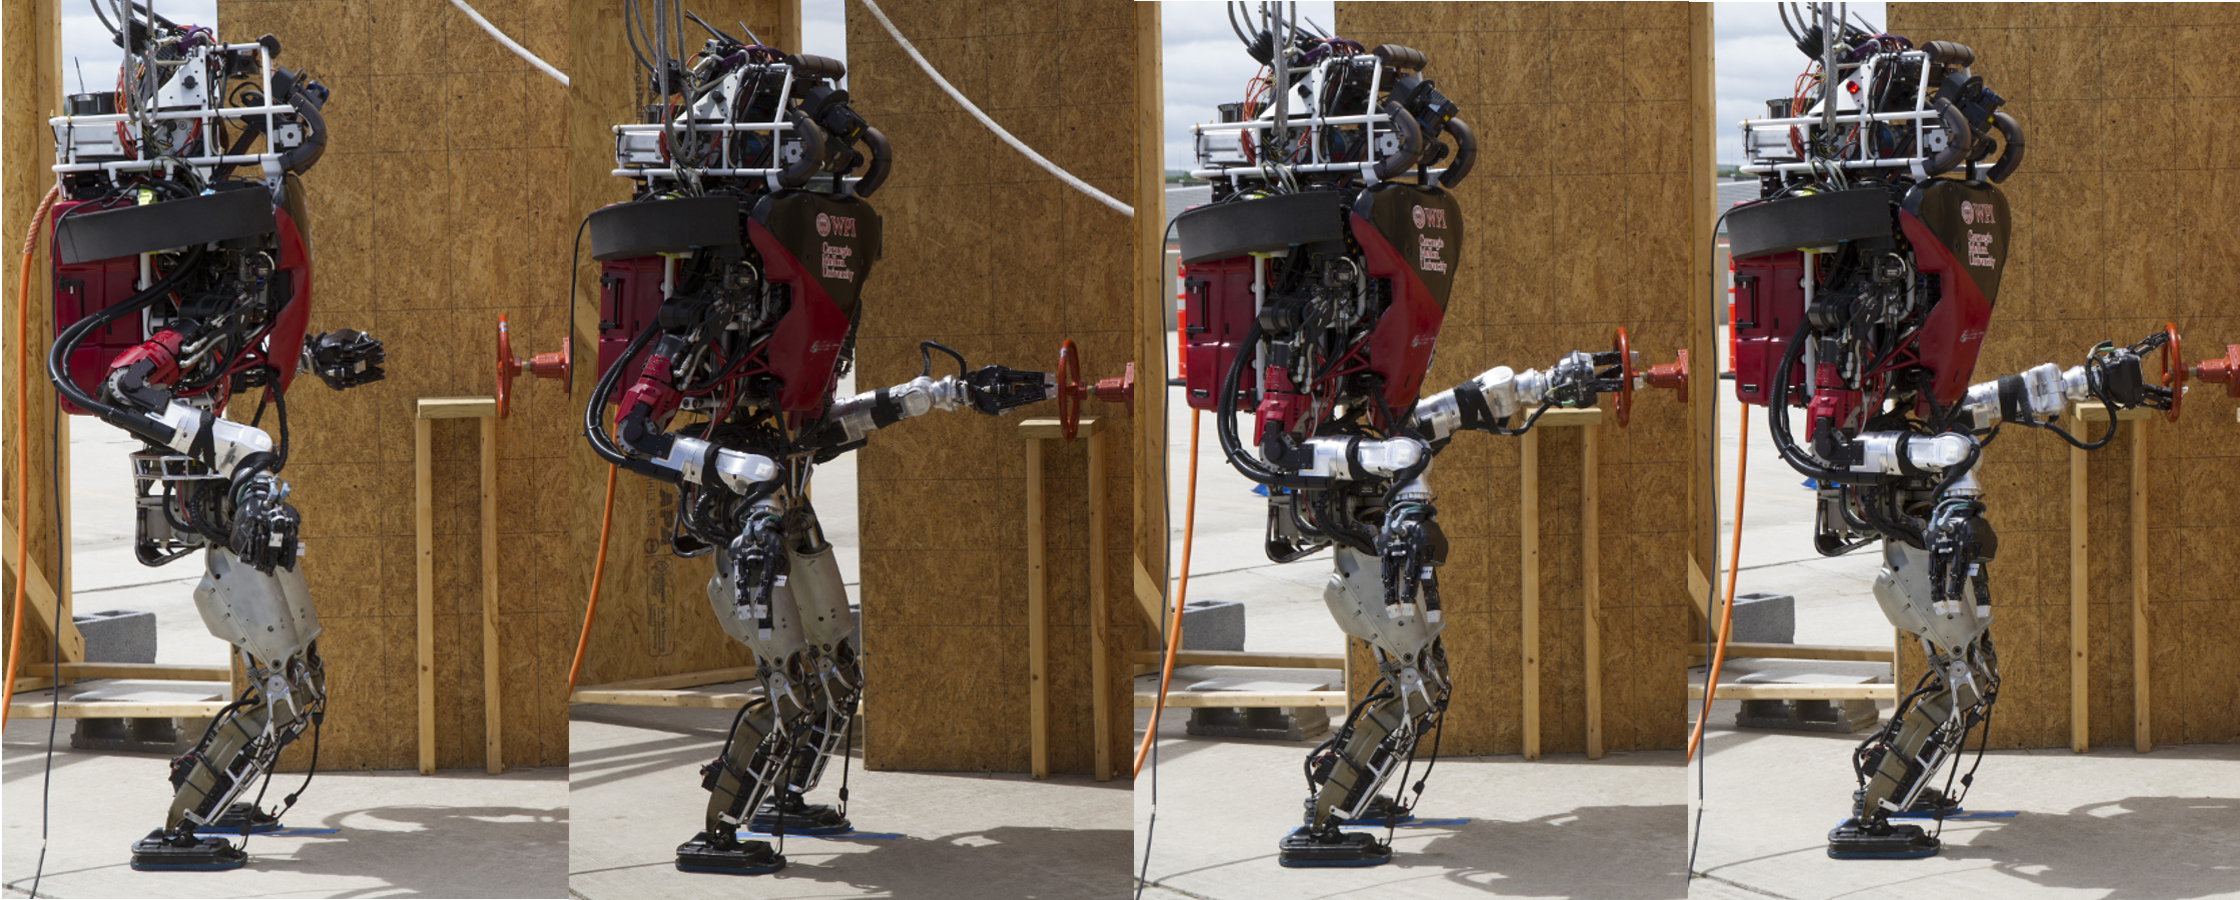
Manipulation Lead for the WPI-CMU team in the DARPA Robotics Challenge. I led full-body motion planning for the 30-DoF Boston Dynamics Atlas humanoid robot, coordinating a team of graduate and undergraduate students through the DRC Trials and Finals.

Press and video

Education

M.S. Robotics Engineering

Worcester Polytechnic Institute, 2014

GPA: 4.0

B.S. Electrical & Computer Engineering / Robotics Engineering

Worcester Polytechnic Institute, 2011

GPA: 3.8
03

Patents

US 12,528,653 · FIG. 3

Concentric suction cup tool

Three of the patents below cover parts of this one tool. Hover or tap a highlighted part to see which.

310Shell
320Vacuum manifold cap
330Vacuum manifold
332Brake air path
350Brake assembly
360Pistons
370Suction cups
18Granted US patents

One issued at Reframe Systems, covering matrix manufacturing with robotic work cells. Seventeen issued from my work at Amazon Robotics, covering robotic grasping, end-of-arm tooling, manipulation systems, and safety. View all on Google Patents

Factory Automation (Reframe Systems)

  • US12715136Systems and methods of matrix manufacturing with work cells

Robotic Grasping & End-of-Arm Tools

  • US12528653Concentric suction cup tools with integrated air chambers
  • US12428243Concentric suction cup tools with integrated brake assemblies
  • US11492215Concentric suction cup tools with parallel pistons
  • US11351678Dynamically adjustable suction cups
  • US11207786Concentric suction cup array for end-of-arm tool
  • US11084175End-of-arm tool having concentric suction cups
  • US11077564Toroidal suction grippers
  • US10933537End of arm tool including feedback
  • US10611580Concentric suction cup array including actuators and compliance
  • US10611037Concentric suction cup array for end-of-arm tool
  • US10059007Finger-aligned extendable gripping mechanisms for item manipulation

Manipulation Systems & Robotics Infrastructure

  • US12194627Modular robotic manipulation systems
  • US11865727Robotic picking assemblies with different concurrent flow rates
  • US11623339Portable robotic manipulation systems
  • US11534923Robotic manipulation and frame sensor placement for in-motion object modeling

Safety & Calibration

  • US11912513Robotic system camera calibration and localization using robot-mounted registered patterns
  • US11279035LIDAR safety rings
04

Publications

  1. 01

    ARMBench: Amazon Robotic Manipulation Benchmark

    Chaitanya Mitash, Fan Wang, Shiyang Lu, Vikedo Terhuja, Tyler Garaas, Felipe Polido, Manikantan Nambi, ICRA 2023.

  2. 02

    Human-Supervised Control of the ATLAS Humanoid Robot for Traversing Doors

    Nandan Banerjee, Xianchao Long, Ruixiang Du, Felipe Polido, Siyuan Feng, Christopher Atkeson, Michael Gennert, Taskin Padir, IEEE Humanoids 2015.

  3. 03

    Team WPI-CMU: achieving reliable humanoid behavior in the DARPA Robotics Challenge

    Christopher G. Atkeson, Benzun P. W. Babu, Nandan Banerjee, et al. including Felipe Polido, Journal of Field Robotics.

  4. 04

    Human-in-the-loop Control of a Humanoid Robot for Disaster Response

    DeDonato, M., Dimitrov, V., Du, R., et al. including Polido, F., Journal of Field Robotics 2015.

  5. 05

    NO FALLS, NO RESETS: Reliable humanoid behavior in the DARPA Robotics Challenge

    Christopher G. Atkeson et al. including Felipe Polido, 15th IEEE-RAS International Conference on Humanoid Robots (2015).

  6. 06

    What Happened at the DARPA Robotics Challenge, and Why?

    Christopher G. Atkeson et al. including Felipe Polido, DRC Finals Special Issue of the Journal of Field Robotics (2015).

05

Get in touch

Interested in Reframe Systems, robotics, or just want to connect? Reach me at felipe.polido@gmail.com or find me on LinkedIn and X.